news
188
AlphaNIST
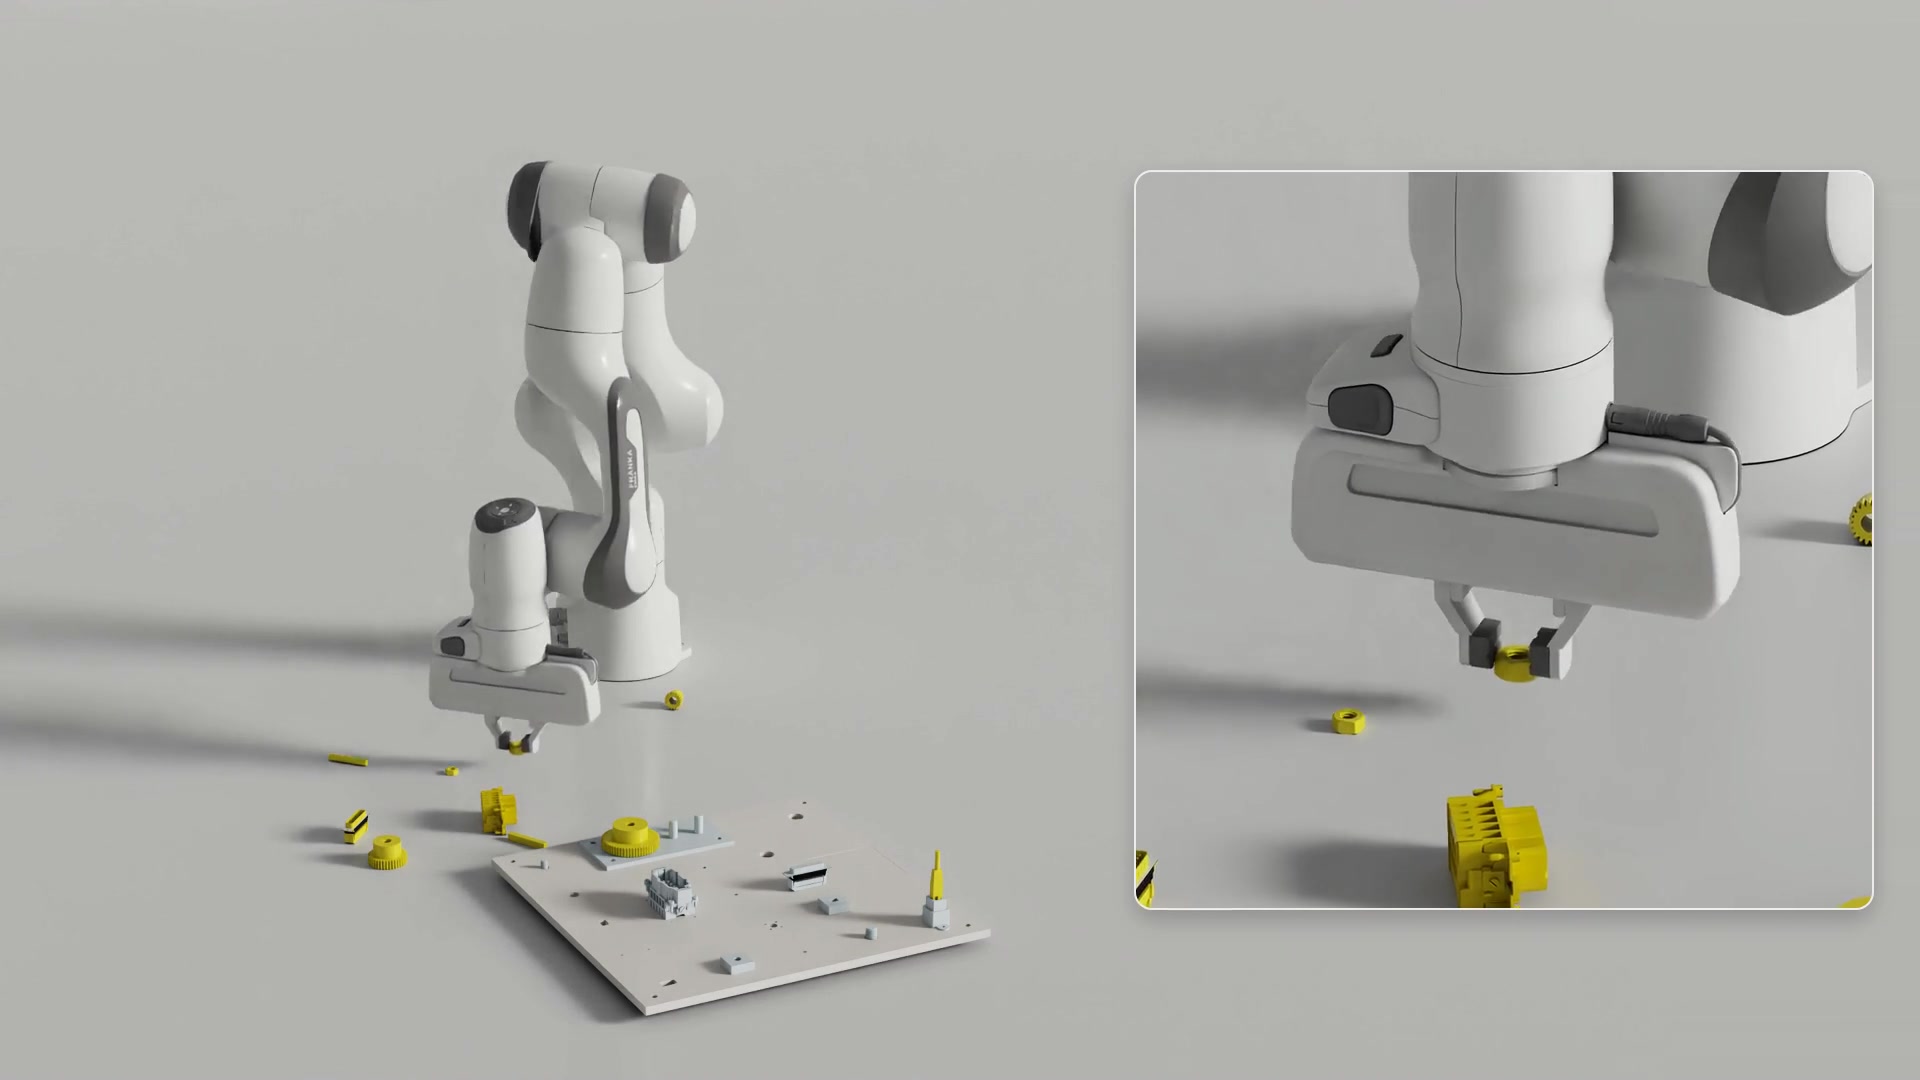
2026-10-14AlphaNIST introduces a novel method for teaching robotic dexterity and coordination entirely within simulated environments. The system leverages large-scale training, cached starting states, and binary task rewards to learn complex manipulation skills without relying on predefined procedural stages. This streamlined approach could significantly accelerate the development of highly adaptable and capable robotic systems.
Comments
0Discuss on Hacker NewsOnly full members can comment
Log in to express your opinion.
No comments yet.